

ElectroHMI - Testbed for stiffness-aware control of a compliant robot gripper based on electrotactile feedback as a human-machine interface
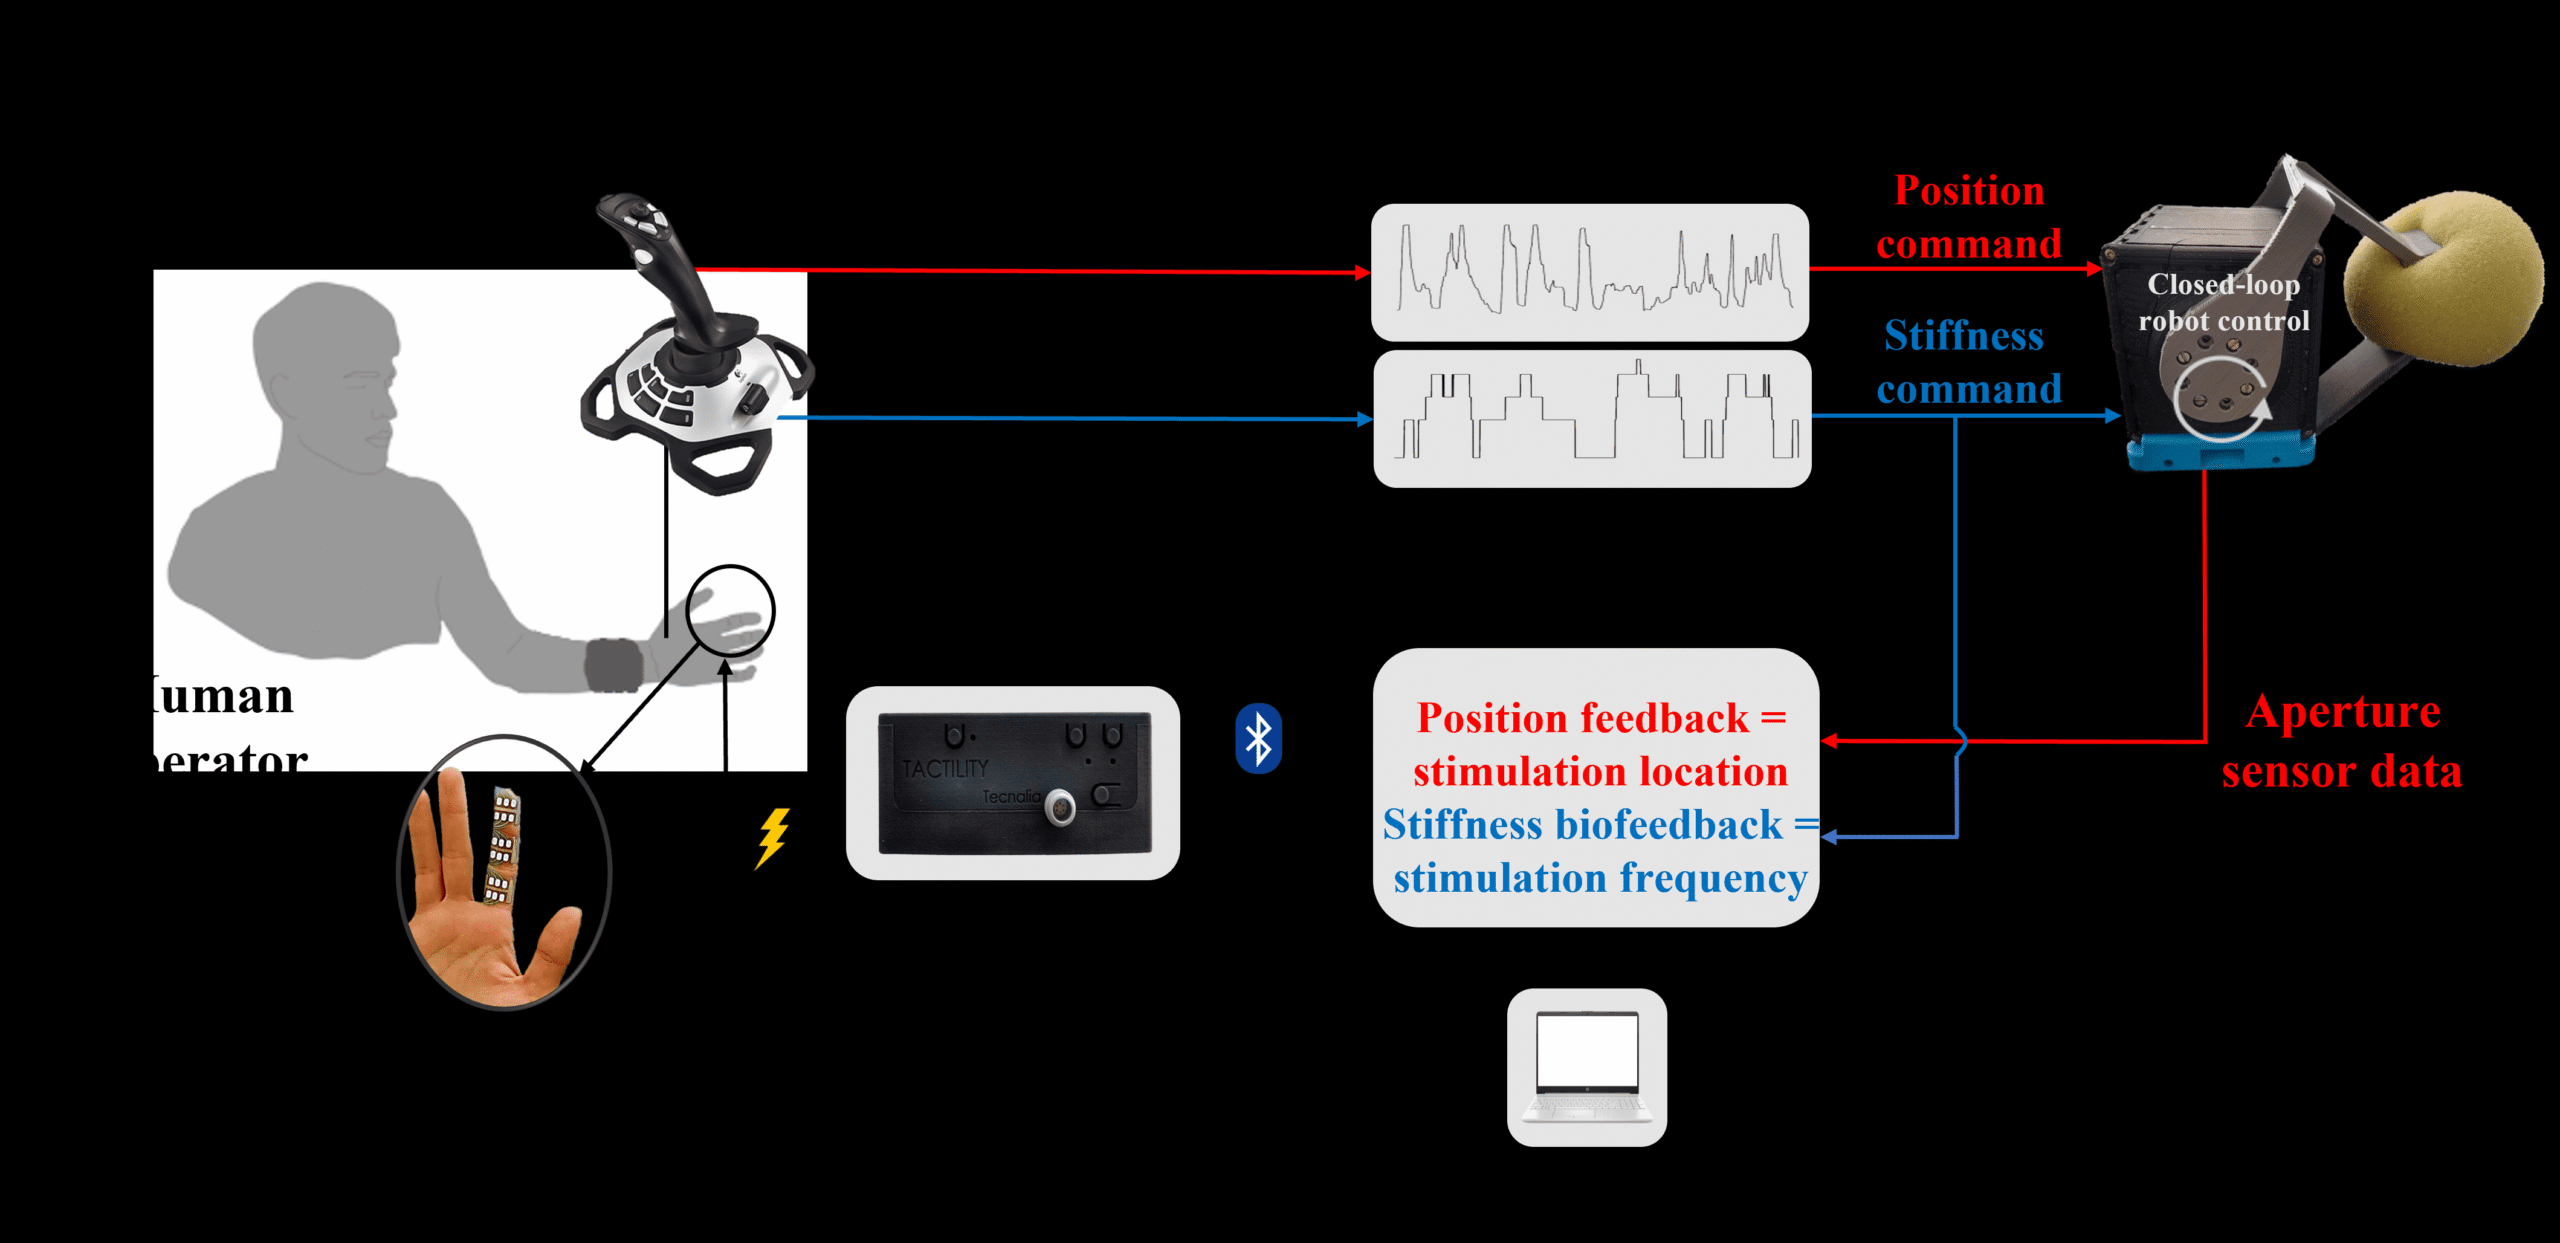
In the TestBed, we designed and developed a high-resolution, compact system delivering electrotactile stimulation to the finger for the closed-loop control of a variable stiffness robot gripper. The feedback conveys information about both gripper aperture and commanded stiffness by modulating the location and frequency of stimulation, respectively. The explicit information about the position and stiffness of a compliant actuator was envisioned to provide better force control without the need to measure and feed back the contact forces between the gripper and the object.
TestBed provides accurate positioning of the gripper without any visual cues. Moreover, stiffness feedback prevents dangerous and harmful grasps, allowing the operator to evaluate the commanded stiffness directly and adjust it proactively. This TestBed underlines stiffness as a primary determinant of safe and effective grasping in robots and demonstrates that even minimal cutaneous feedback can support informed modulation of grasp behavior.
| Name of Principal Investigator: | Prof. Dr. Kosta Jovanovic |
| Position / institutional role: | Associate professor |
| Info Email: | kostaj@etf.rs |
| ORCID persistent identifier (PID): | 0000-0002-9029-4465 |
| Name of Host Organization | University of Belgrade – School of Electrical Engineering (ETF) |
| Department or Lab | Department of Signals and Systems, ETF Robotics lab |
| Name of Building | Palace of Science |
| Physical Address | Kralja Milana 11, 11000 Beograd, Serbia |
| Website Links | https://robot.etf.bg.ac.rs |
| Institutional contact name | Prof. Dr. Kosta Jovanovic |
| Institutional contact email | kostaj@etf.rs |
| Non-academic stakeholders |
| Industrial Partners; Startups; SMEs |
| Academic stakeholders |
| Undergraduate students; PhD students; MSc students; Researchers |
| Other types of stakeholders |
| robotics integrators, haptics developers, medical-device and rehabilitation technology developers, HRI labs, haptics labs, control systems researchers |
| Application case: | Short description: |
| Research and educational use for improving feedback clarity and bio-inspired control | supports experiments on grasping objects of different characteristics, improving anticipation of object fragility, reducing slip or damage, and exploring alternative feedback coding strategies and stimulation locations |
list of hardware components with their brief descriptions:
1. Compliant actuator – one segment of qb move advanced, an agonistic/antagonistic variable stiffness actuator with two fingers forming a gripper; USB and RS485 communication, nominal torque 5.5 Nm, nominal speed 5.5 rad/s, nominal voltage 24 V, variable stiffness range 0.5-83.5 Nm/rad, active rotation angle +/-180 degrees, weight 0.45 kg, dimensions 66x66x66 mm.
2. Logitech Extreme 3D PRO joystick – used for operator control; 12 programmable buttons, 8-way hat switch, twist rudder control.
3. Electrotactile stimulation system – three matrix electrodes with six pads each plus a stimulation unit generating current-controlled biphasic charge-balanced pulses with configurable pulse width, pulse rate, and amplitude.
4. Laptop PC with Windows OS 2008 or newer.
list of software components with their brief descriptions:
1. MATLAB and Simulink 2020a or newer with installed qbmove Simulink libraries.
2. qb API C++ Libraries for control and parameter setting of the qb move advanced robot.