

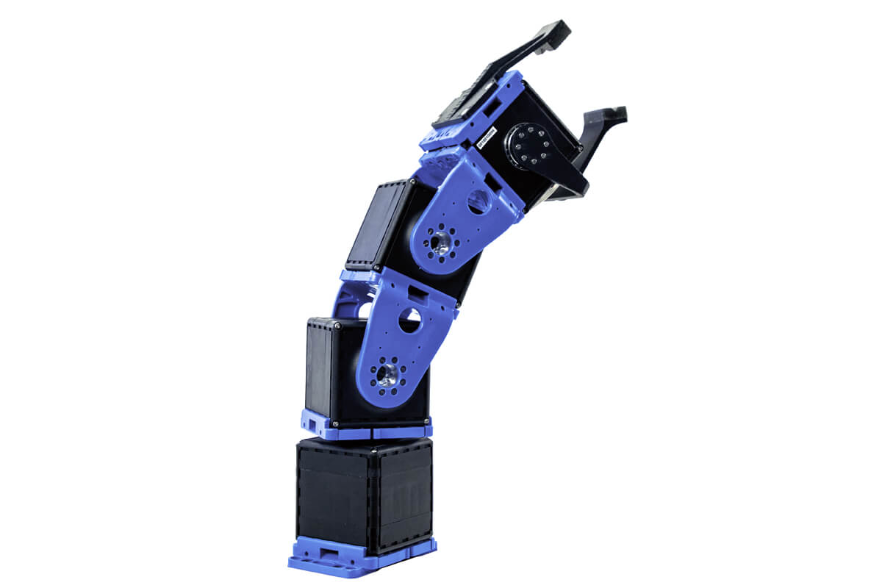
Setup for control, modelling, and algorithm testing of variable stiffness actuators (VSAs)
A modular neuroergonomic workstation for human-centered, collaborative manual assembly. The setup combines portable EEG-based mental workload assessment (BrainWatch), a nonintrusive hand-gesture interface (Leap Motion–based M2O2P-L), an adaptive graphical instruction system (ADIN), and a collaborative robot assistant (Franka Emika Panda) that delivers the right parts at the right time. All modules are integrated through FIWARE middleware (Orion Context Broker) and can be extended with a smart task scheduler for workload-aware task allocation. The concept was validated as a proof-of-concept in a real factory environment for assembly of fiscal devices, showing fewer errors and lower mental demand with cobot-supported assembly, while maintaining comparable cycle times. The workstation is designed for easy deployment and reconfiguration across assembly variants, supporting onboarding of new workers and improving well-being and productivity in Industry 5.0 contexts.
| Name of Principal Investigator: | Branko Lukić |
| Position / institutional role: | Research associate |
| Info Email: | branko@etf.rs |
| ORCID persistent identifier (PID): | 0000-0003-0430-6560 |
| Name of Host Organization | University of Belgrade – School of Electrical Engineering (ETF) |
| Department or Lab | Department of Signals and Systems, ETF Robotics lab |
| Name of Building | Palace of Science |
| Physical Address | Kralja Milana 11, 11000 Beograd, Serbia |
| Website Links | https://robot.etf.bg.ac.rs |
| Institutional contact name | Prof. Dr. Kosta Jovanovic |
| Institutional contact email | kostaj@etf.rs |
| Non-academic stakeholders |
| Startups; |
| Academic stakeholders |
| PhD students; MSc students; Researchers |
| Other types of stakeholders |
| Application case: | Short description: |
| Robot Control & Manipulation Tasks | Programming robot motion and testing control algorithms while controlling the position and stiffness of each qb Advanced VSA, and exploiting available measurements and datasets. |
list of hardware components with their brief descriptions:
4 pieces of qb move advanced AGONISTIC/ANTAGONISTIC SERVO-VSA (qb move advanced kit) | Output Power [33W] | Nominal Torque [5,5Nm] | stiffness range [0.5-83.5 Nm/rad] | Active Rotation Angle [±180°] | Angular Resolution [360/32768°] | Weight [0,45 Kg] | Nominal Voltage 24V | USB & RS485 communication| Dimensions 66x66x66mm.
list of software components with their brief descriptions:
MATLAB (2015b or newer)
qb API C++ Libraries
Virtual COM Port Drivers
qbmove Simulink Libraries
GUI – Windows
Windows 10 or Windows 11