НАСЛОВНА
О НАМА
Тим
Рад са индустријом
Партнери
ЛАБОРАТОРИЈА
TESTBEDS
Образовни рад
ИСТРАЖИВАЧКИ РАД
Физичка интеракција човека и робота
Меки роботи (soft robotics)
Дигитална биомеханика и ергономија
Виртуелна реалност у роботици
ПУБЛИКАЦИЈЕ
ПРОЈЕКТИ
НОВОСТИ
КОНТАКТ
НАСЛОВНА
О НАМА
Тим
Рад са индустријом
Партнери
ЛАБОРАТОРИЈА
TESTBEDS
Образовни рад
ИСТРАЖИВАЧКИ РАД
Физичка интеракција човека и робота
Меки роботи (soft robotics)
Дигитална биомеханика и ергономија
Виртуелна реалност у роботици
ПУБЛИКАЦИЈЕ
ПРОЈЕКТИ
НОВОСТИ
КОНТАКТ
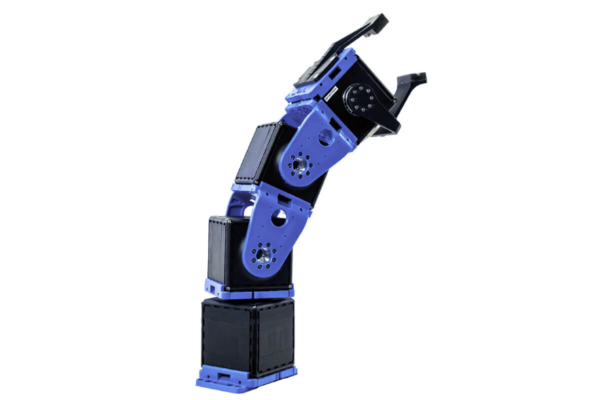
Setup for control, modelling, and algorithm testing of variable stiffness actuators (VSAs)
Setup for control, modelling, and algorithm testing of variable stiffness actuators (VSAs)
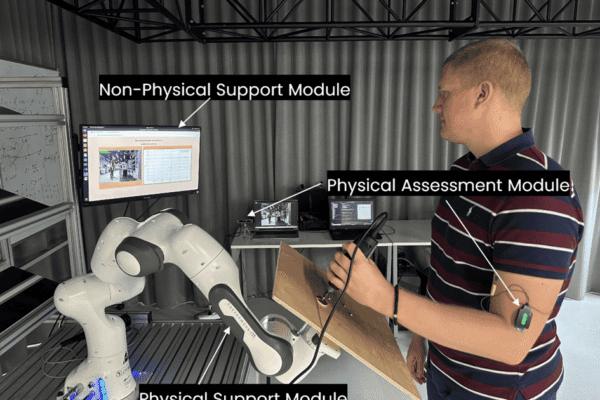
Ergonomic workstation for collaborative polishing – A Vision-Based Framework for Real-Time Fatigue-Aware Adaptation in Physically Intensive Human-Robot Collaboration
Ergonomic workstation for collaborative polishing – A Vision-Based Framework for Real-Time Fatigue-Aware Adaptation in Physically Intensive Human-Robot Collaboration
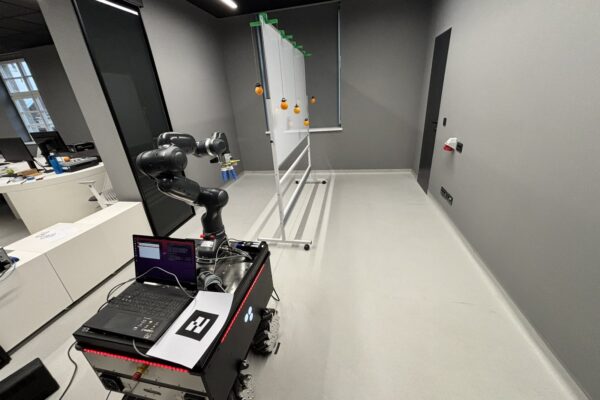
MobilePlan – Optimization-powered mobile manipulation task planning for agriculture pick-and-carry tasks
MobilePlan – Optimization-powered mobile manipulation task planning for agriculture pick-and-carry tasks
ElectroHMI – Testbed for stiffness-aware control of a compliant robot gripper based on electrotactile feedback as a human-machine interface
ElectroHMI – Testbed for stiffness-aware control of a compliant robot gripper based on electrotactile feedback as a human-machine interface
Neuroergonomic Cobot-Assisted Manual Assembly Workstation
Neuroergonomic Cobot-Assisted Manual Assembly Workstation
Dual Robot Industry 4.0 Workstation
Dual Robot Industry 4.0 Workstation
Autonomous Mobile Robot TurtleBot3 TestBed
Autonomous Mobile Robot TurtleBot3 TestBed
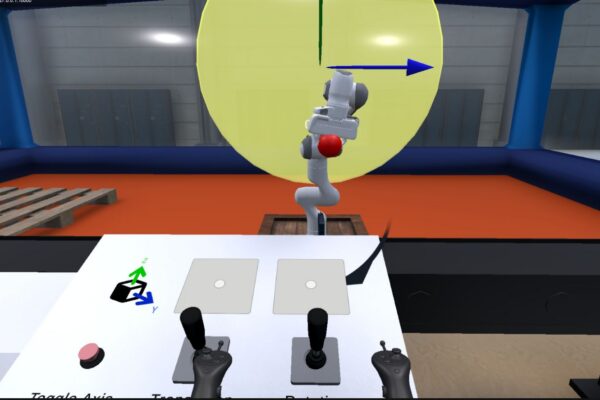
VR Training for Collaborative Robots TestBed
VR Training for Collaborative Robots TestBed
XR Neuroergonomic Cobot-Supported Manual Assembly TestBed
XR Neuroergonomic Cobot-Supported Manual Assembly TestBed
IsaacSim-Nav: High-Fidelity Digital Twin Platform for Autonomous Navigation
IsaacSim-Nav: High-Fidelity Digital Twin Platform for Autonomous Navigation
1
2
Следећа страна »
2019 Theme - WordPress Theme built by
Mintithemes
using
WordPress
.