

From November 22 to 24, the IEEE RAS HUMANOIDS Conference brought together global leaders in humanoid robotics in Nancy, France. This premier event showcased cutting-edge advancements in robot design, control, perception, learning, and human-robot interaction, alongside workshops, tutorials, industrial exhibitions, and robotics competitions.
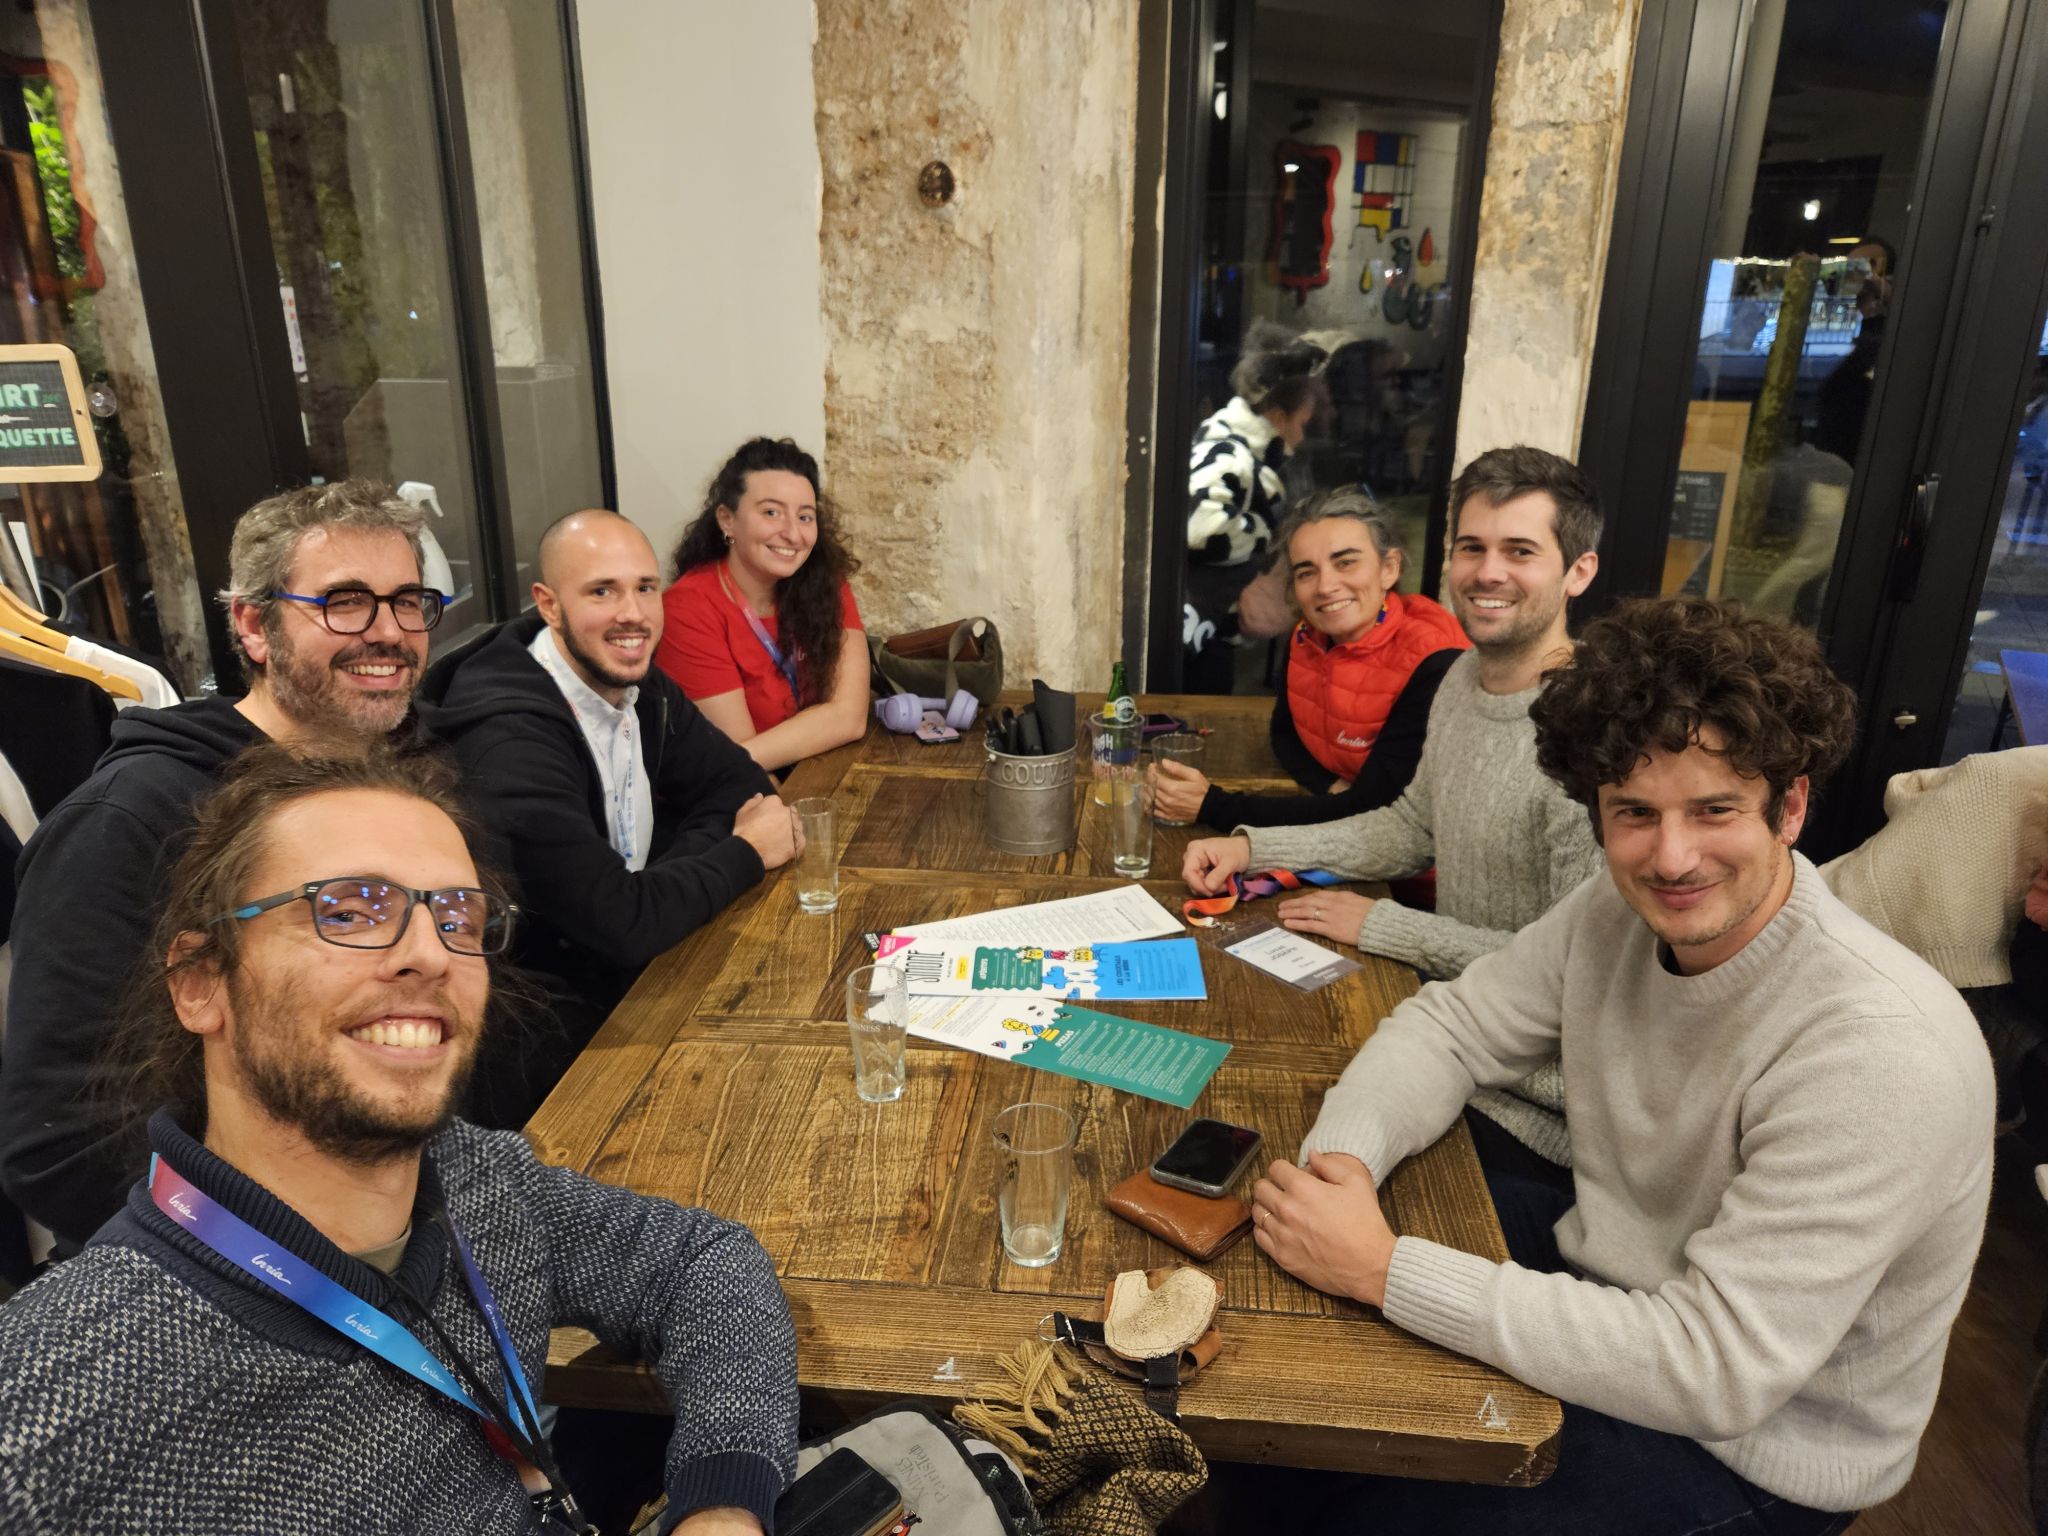
The conference was an incredible opportunity to reconnect with colleagues from LAAS-CNRS, Inria Paris, Inria Bordeaux, Inria Montpellier and other leading institutions while building new collaborations and exploring the latest technologies from innovators like Booster Robotics, DLR, Ghost Robotics, IIT, PAL Robotics, Unitree, and Wandercraft.
Our colleague Filip Bečanović contributed to this inspiring event by presenting a poster on his novel work in inverse optimal control (IOC) – „Reliability of Single-Level Equality-Constrained Inverse Optimal Control“. Filip used a single-level reformulation of the traditional bilevel IOC method to enhance computational efficiency. This approach achieved a 15-fold reduction in computation time while retaining robustness to noise, enabling learning from human demonstrations of complex motions. This work has the potential to revolutionize how humanoid robots analyze and replicate human behaviors, moving the field closer to seamless human-robot collaboration.
We are grateful to continues collaboration with our colleague Vincent Bonnet and support of Campus France for providing constant support to our promising researchers.
We’re proud of Filip’s contributions and look forward to seeing the impact of his work on the robotics community!

Comments are closed.